


Aotenjo One v2.2
Aotenjo One v2.2
Introducing the Aotenjo One v2.2 BLDC Motor Control Board: Precision Control for Your Automation Projects
Unleash the full potential of your BLDC motors with the Aotenjo One v2.2, a compact and powerful control board designed for robotic, servo, and automation applications. Engineered for smooth, efficient, and precise motion control, Aotenjo One combines an STM32G431 microcontroller, integrated BLDC motor driver, magnetic encoder interface, and CAN FD connectivity in a compact package.
Version 2.2 introduces a switchable CAN termination SPDT switch, replacing the solder jumper used on previous versions. CAN bus termination can now be enabled or disabled directly using the onboard switch, making it much easier to configure the board's position within a CAN network.
Key Features:
- Powerful Microcontroller: Driven by the STM32G431CB (170 MHz, 128 KB Flash, 32 KB RAM), providing ample processing power for motor control algorithms.
- Robust Motor Driver: Built around the DRV8313, capable of delivering up to 2.5 A peak current for dynamic motor response.
- Integrated Position Feedback: Features a 14-bit magnetic encoder interface for high-resolution angle sensing and precise closed-loop control.
- Advanced Communication: Supports CAN FD for fast and efficient communication between multiple motor controllers. I²C, UART, and SPI interfaces are also available for flexible system integration.
- Switchable CAN Termination: An onboard CAN termination SPDT switch allows the termination resistor to be enabled or disabled without soldering. Enable termination when the Aotenjo One is located at the end of the CAN bus, or disable it when the board is positioned in the middle of the network.
-
VSENSE Voltage Monitoring: The VSENSE feature enables real-time VCC voltage monitoring through the STM32G431's ADC, useful for diagnostics and power-aware applications.
Technical Specifications:
MCU: STM32G431CBU6 (170MHz, 128KB Flash, 32KB RAM)
Motor Driver: DRV8313PWPR
Motor Compatibility: Recommended for motors with internal resistance > 10 Ω
CAN Transceiver: TCAN3413 (3.3V operation)
Voltage Input: 8-35v
Encoder Interface: 14-bit Magnetic Encoder
Communication Interfaces: CAN, I²C, UART, SPI
Power Interface: 2x JST XH
CAN Interface: 2x JST PH
CAN Network Termination: Switchable onboard termination via SMD SPDT switch
User Interface: 1x User Button, 1x NRST Button (configurable as user button)
Indicators: 1x Blue LED, 1x Red Power Indicator LED, 1x Red Driver Fault Indicator LED
Mounting: 3 x M2.5 holes
CAN Termination & Network Placement
A CAN bus should be terminated at both physical ends of the network.
Previous Aotenjo One versions used an onboard solder jumper to configure the termination resistor. With Aotenjo One v2.2, this has been replaced by an SMD SPDT switch, allowing termination to be changed instantly without soldering.
- Aotenjo One at the end of the CAN bus: Enable CAN termination.
- Aotenjo One in the middle of the CAN bus: Disable CAN termination.
This makes it easier to add, remove, or reposition Aotenjo One boards when building or modifying a multi-motor CAN network.
What's Included:
- 1x Aotenjo One Board v2.2
- 1x CAN Bus Cable(20cm / 7.87 inches, 28AWG, JST PH 2-pin connector on both ends, green/yellow wires) - for connecting CAN nodes
- 1x Main Power Input Cable (10cm / 3.94 inches, 22AWG, JST XH 2-pin connector on one end with bare leads on the other, red/black wires) - for connecting to a power supply
- 1x Power Daisy-Chain Cable (20cm / 7.87 inches, 22AWG, JST XH 2-pin connector on both ends, red/black wires) - for connecting to Aotenjo One boards or similar
- 1x Diametrically magnetized disc magnet (6 x 2.5mm)
Important Notes:
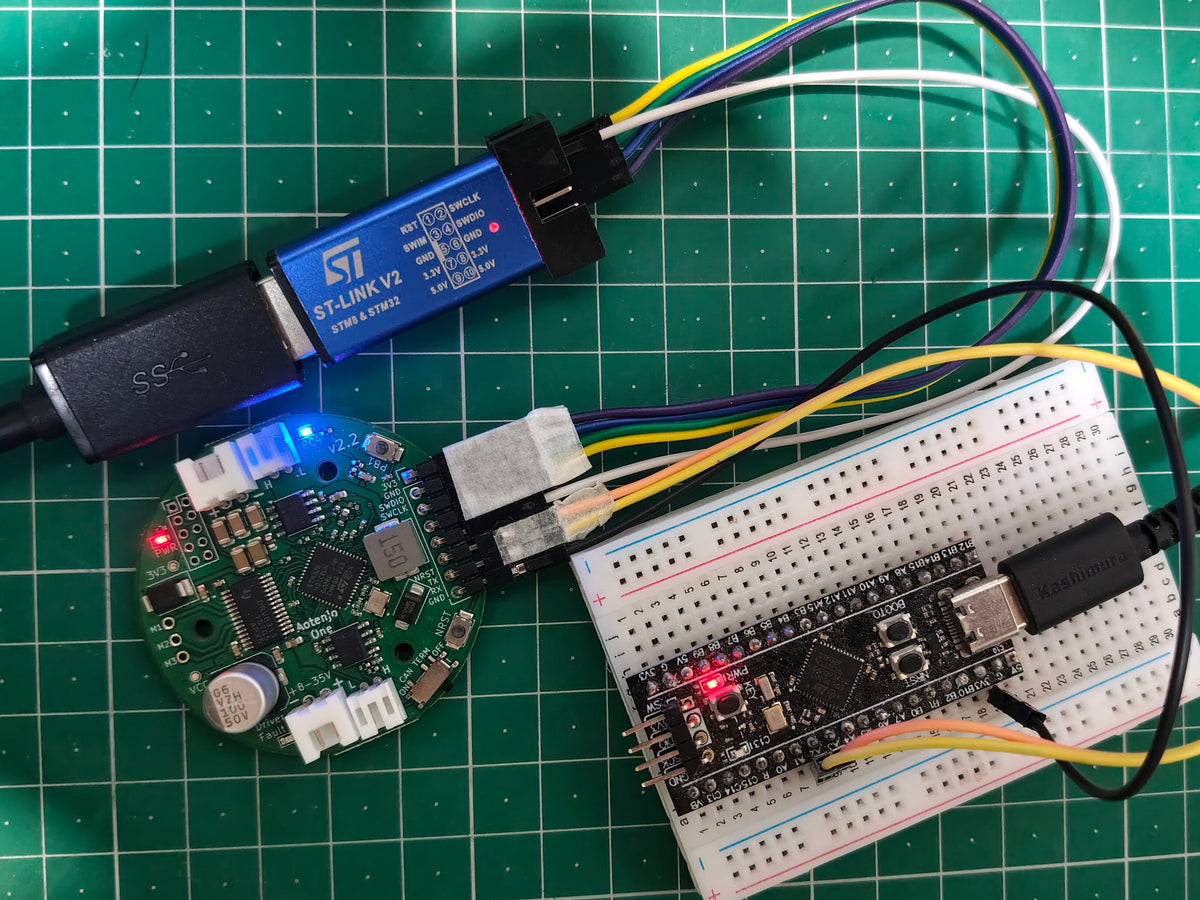
- To program this board, you will need an ST-LINK V2 Clone (or compatible programmer).
- Proper CAN bus termination is required for reliable communication. Enable termination only when the board is located at a physical end of the CAN bus.
- Compatibility Alert: This board is specifically designed for motors with internal resistance greater than 10 Ω. It is NOT suitable for typical low-resistance drone motors. Using incompatible motors may lead to unexpected behavior or damage.
The Aotenjo One v2.2 provides compact, precise BLDC motor control with flexible CAN FD networking—making it a strong foundation for multi-axis automation, robotics, and custom motion-control systems.
Couldn't load pickup availability
22 in stock
View full details


Frequently Asked Questions
What is the return policy for Aotenjo physical products?
Aotenjo has a 30-day return policy for physical products. Please note that digital products are not eligible for returns. Customers can request a return within 30 days of receiving their item, provided that the product is in its original condition, unworn or unused, and in its original packaging. To initiate a return, customers should contact us via email. For complete details on our return process and refund eligibility, please visit our Refund Policy page.
Can I track my package?
Yes, you will receive an email with tracking information once your order ships. Please allow 1-3 days for the tracking to become active.
When will I receive my order?
For orders shipped within Japan, you can typically expect to receive your package within 2-4 business days.
For international orders, shipping times can vary depending on the destination country's customs procedures and local postal services. While we aim for prompt delivery, please allow for the following estimated delivery times from the date of shipment:
- North America, South America & European Union: 14-21 days
- Asia: 7-12 days (typically 7 days for East Asia, 12-16 days for other regions)
- Oceania: 10-14 days
We use Japan Post's international shipping service, and tracking information will be provided so you can monitor your package's journey.